Könyv Computational optimal control of a biped robot Hayder Al-Shuka

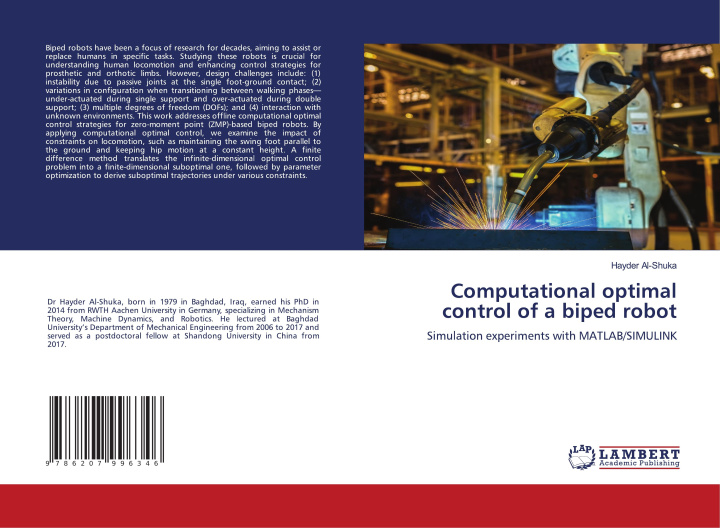
Computational optimal control of a biped robot

Szerző: Hayder Al-Shuka
Nyelv: Angol
Kötés: Puha kötésű
Elérhetőség: Beszállítói készleten
Küldés 5-8 napon belül
15 128 Ft
Biped robots have been a focus of research for decades, aiming to assist or replace humans in specif...
Információk a könyvről

Szerző
Nyelv
Angol
Kötés
Könyv - Puha kötésű
Kiadva
2024
oldal
56
EAN
9786207996346
ISBN
6207996348
Enbook ID
46471483
Súly
102
Méretek
150 x 220 x 4

Teljes leírás

Biped robots have been a focus of research for decades, aiming to assist or replace humans in specific tasks. Studying these robots is crucial for understanding human locomotion and enhancing control strategies for prosthetic and orthotic limbs. However, design challenges include: (1) instability due to passive joints at the single foot-ground contact; (2) variations in configuration when transitioning between walking phases-under-actuated during single support and over-actuated during double support; (3) multiple degrees of freedom (DOFs); and (4) interaction with unknown environments. This work addresses offline computational optimal control strategies for zero-moment point (ZMP)-based biped robots. By applying computational optimal control, we examine the impact of constraints on locomotion, such as maintaining the swing foot parallel to the ground and keeping hip motion at a constant height. A finite difference method translates the infinite-dimensional optimal control problem into a finite-dimensional suboptimal one, followed by parameter optimization to derive suboptimal trajectories under various constraints.

Érdekelheti

2 963 Ft
8 970 Ft
12 852 Ft

Real Mind of God

Robert Stewart
5 631 Ft
6 230 Ft

Azok a vásárlók, akik ezt a könyvet megvásárolták, a következőket is megvásárolták